01 / FIELD DEVICES
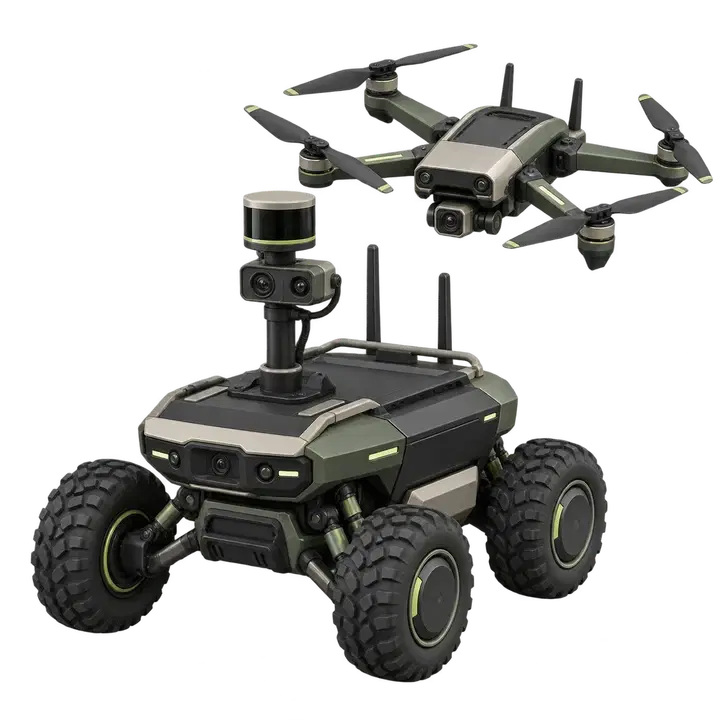
Bring capabilities together
Devices contribute supported functions—movement, sensing, transport, and manipulation—along with video, location, and sensor data.
CoForce is an AI-enabled system in development for coordinating different robots in defense operations. It brings sensing, movement, transport, and manipulation together around operator-defined goals, with a shared view of field conditions and mission progress.
CoForce brings field devices, mission services, and operator views into one system. It connects device capabilities and field information so individual tasks can contribute to the whole mission.
Devices contribute supported functions—movement, sensing, transport, and manipulation—along with video, location, and sensor data.
Mission services coordinate task order and dependencies across devices, using each result to inform what happens next.
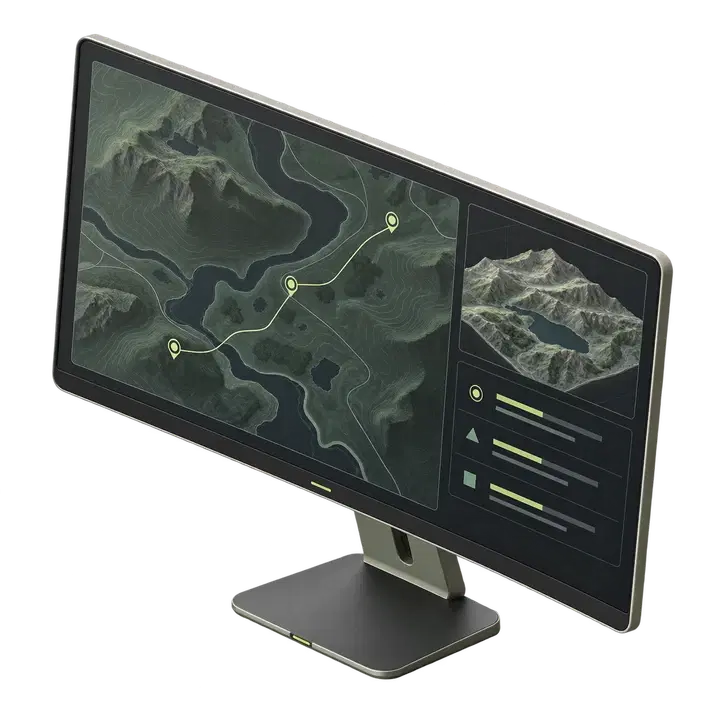
Operators review device locations and task progress in one place, with controls to approve, change, or cancel work.
CoForce connects device roles and task sequences, using results to coordinate the next step—not just show device status.
 Air systems
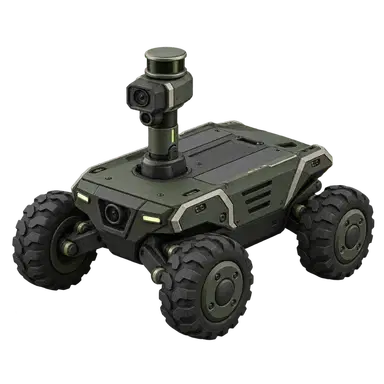 Ground systems
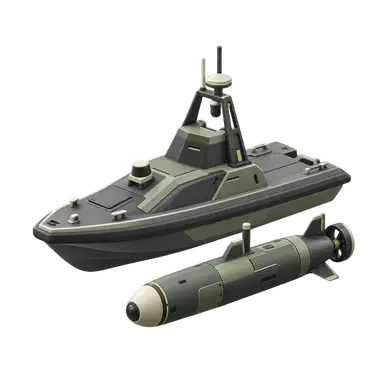 Surface & underwater
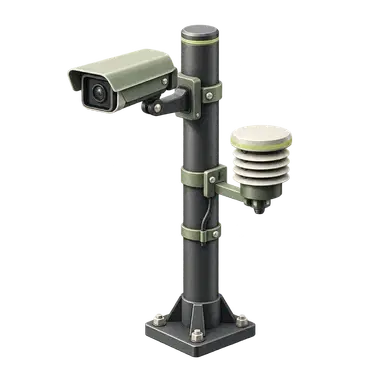 Fixed sensors & observation
CoForce considers device capabilities, task order, and whether work can proceed. Operators set objectives and autonomy limits, with approval required for designated decisions.
Roles are assigned around device capabilities and availability, helping operators bring the right capabilities to the mission.
The system accounts for task dependencies and shared resources, coordinating handoffs so operators can focus on the overall workflow.
CoEgent, the device-side AI, shares status and execution constraints. When work cannot proceed as requested, that feedback informs the next assignment or sequence.
Operators set objectives and approval conditions. The system is designed to distinguish delegated work from decisions requiring human input, with options to change or cancel tasks.
Mission agents coordinate the team. CoEgent assesses each request onboard, using device and field conditions. The two roles exchange tasks, status, and results.
Operators define autonomy limits and approval rules. This division of roles works with each device’s own control and autonomy functions.
CoForce feeds results and field conditions back into the plan. Objectives, assignments, execution, and review stay connected so operators can follow the mission as it evolves.
Operators set the objective, operating area, task conditions, and approval rules. AI uses these to prepare the task plan.
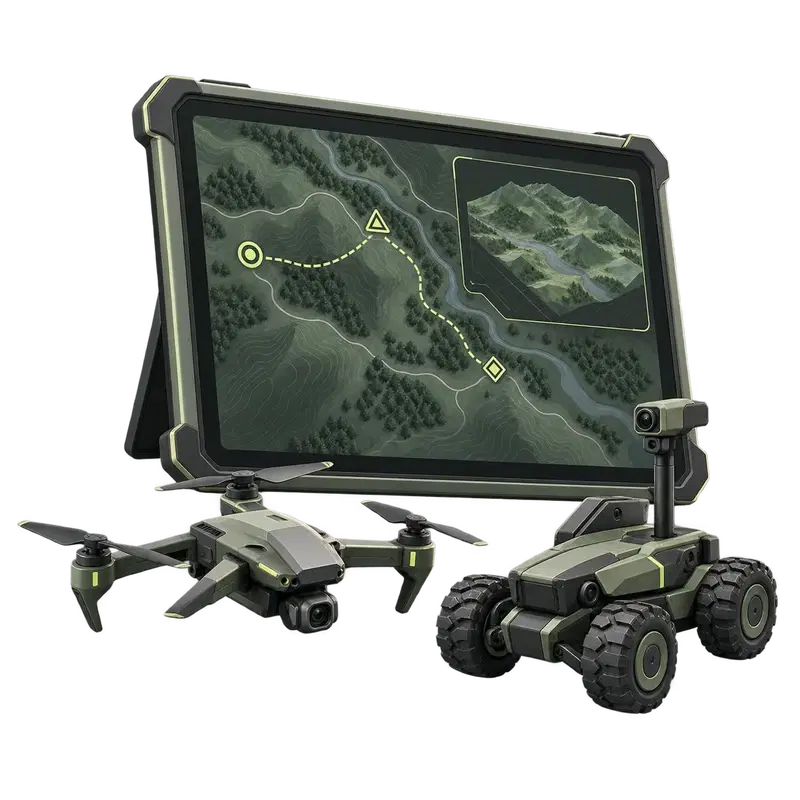
Device locations, status, sensor data, and task progress come together in a 2D/3D common operating picture (COP), giving operators shared context for decisions.
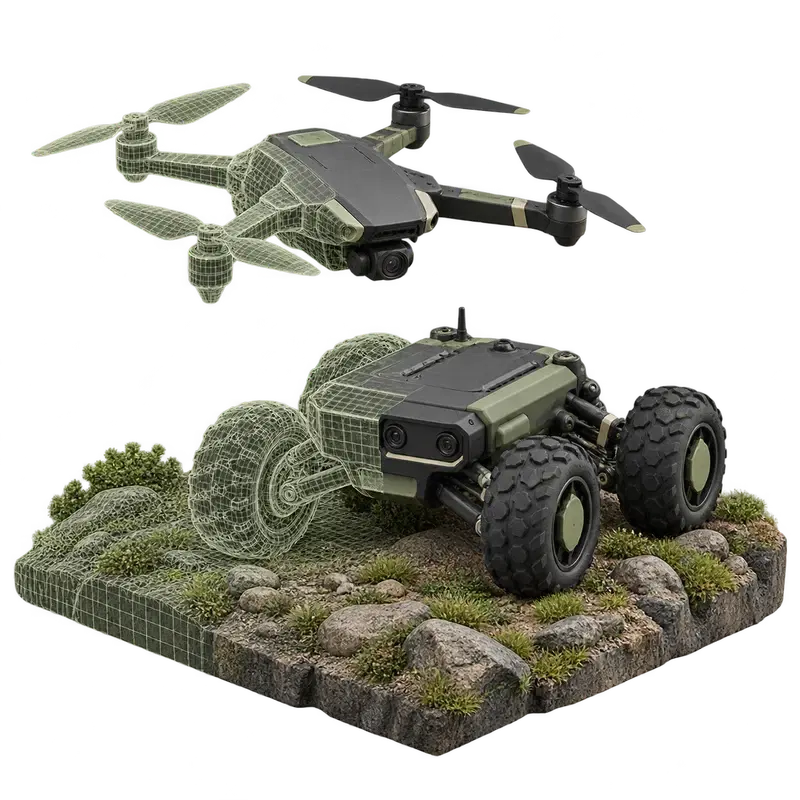
Testing progresses from simulation to physical devices and mixed environments. Each stage helps assess integration and mission workflows before field deployment.
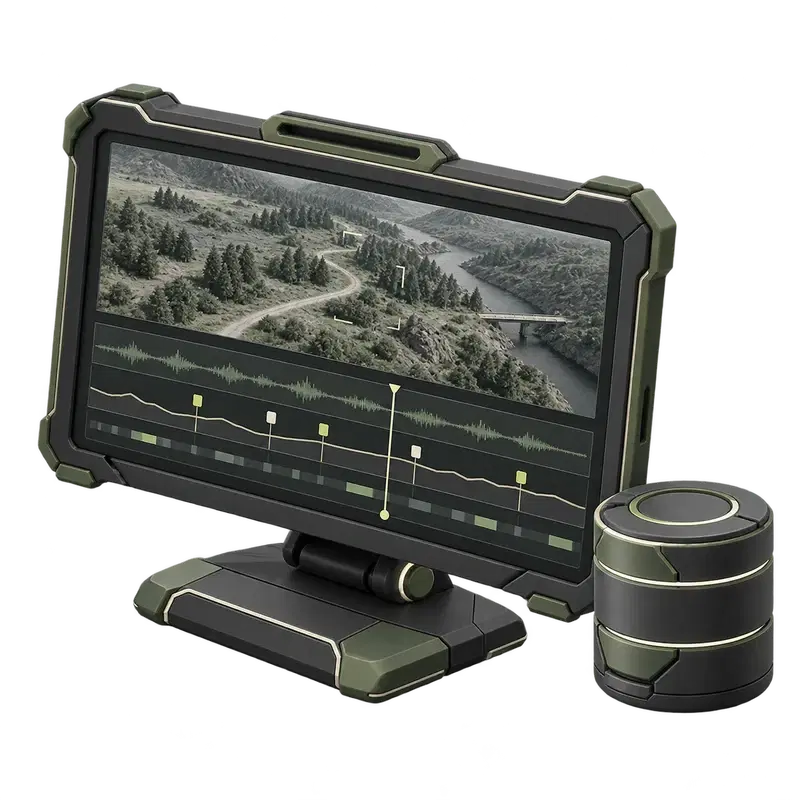
Video, sensor data, events, and task history can be replayed on a shared timeline. After-action review (AAR) helps teams investigate what happened and identify improvements.
Integration starts with the connections existing and new devices provide, and the information needed from command and data systems. Connectivity and local processing needs guide where functions run.
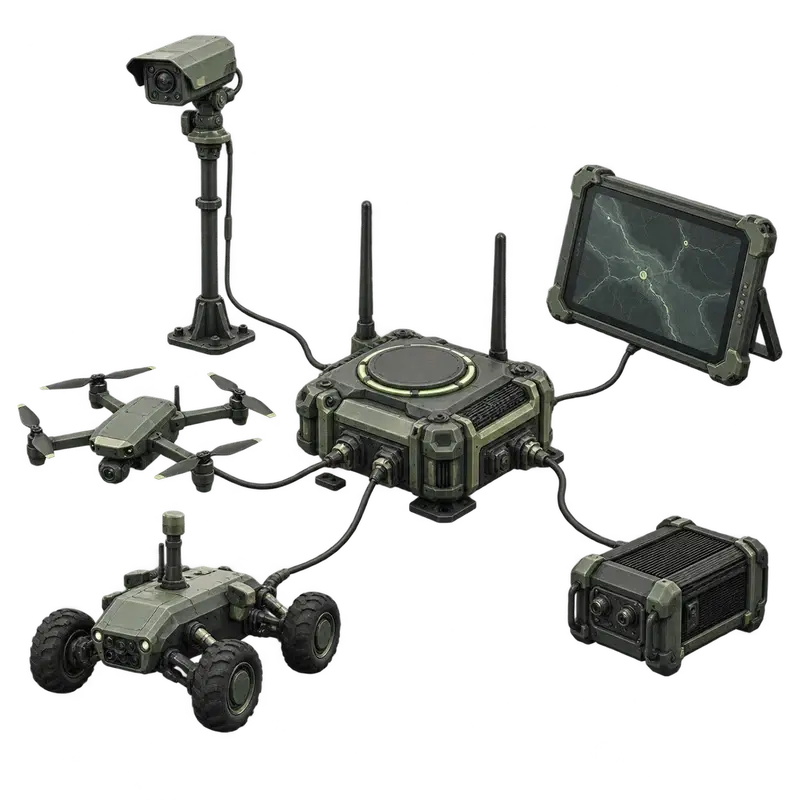
Device Adapters translate shared task requests into device-specific commands and return status and results. Integration scope depends on the connections and capabilities each device provides.
External command and data systems connect separately from device control. The information exchanged is defined for each operating environment.
Functions can run centrally or, where needed, on a field server. Connectivity and local processing needs guide the setup.
Mission services use shared task rules. Device Adapters translate requests into the commands and data formats each device uses, then return status and results.
Request tasks and track progress through common rules
Translate between shared rules and device commands and data
Connect through the interfaces a device provides, such as ROS, MAVLink, or a manufacturer’s SDK/API.
Choose service placement around connectivity and the functions needed in the field. A field server is not required in every deployment.
Devices connect directly to central mission services, with device control and autonomy remaining onboard.
Place selected coordination or recording services on a field server while keeping a connection to central services.
Integration scope depends on device capabilities, available interfaces, and operating conditions.
CoForce is in development. Contact us to confirm current capabilities and whether a demonstration or test is available. We welcome discussions about application fit, device integration, and joint testing.
We assess integration around the control and data interfaces, and autonomous functions, that a device provides. Support is not automatic for every device; prerequisites and any required changes need to be reviewed together.
No. The choice depends on connectivity and the functions needed in the field.
Compare deployments and connection-loss conditionsShare your objectives, device types and available interfaces, and operating environment. It is fine if some details are undecided; we can identify what to check first and define a joint test scope together.
We welcome defense teams, system integrators, and device developers to explore mission fit. Share your objectives, target devices, and operating environment to discuss integration and joint testing.
Outline the work, devices, and operating environment.
Check device interfaces and the capabilities currently available.
Agree on what to evaluate first, test conditions, and responsibilities.